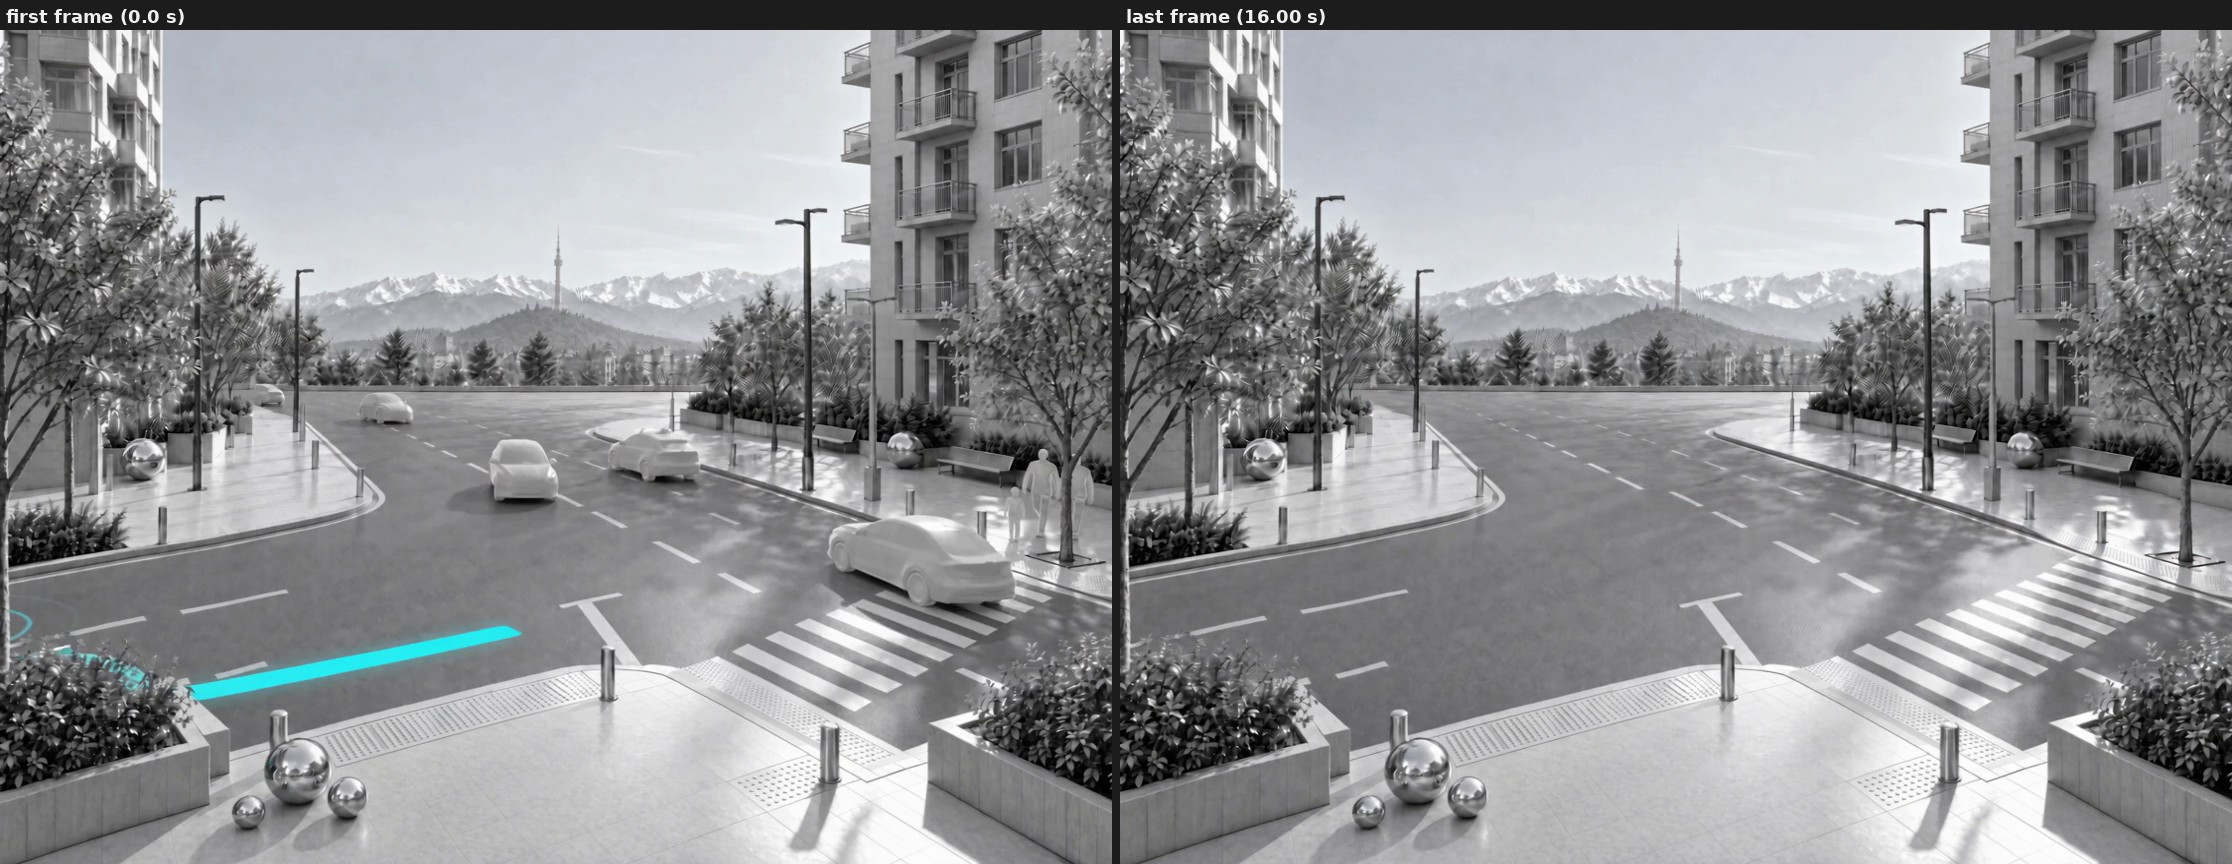
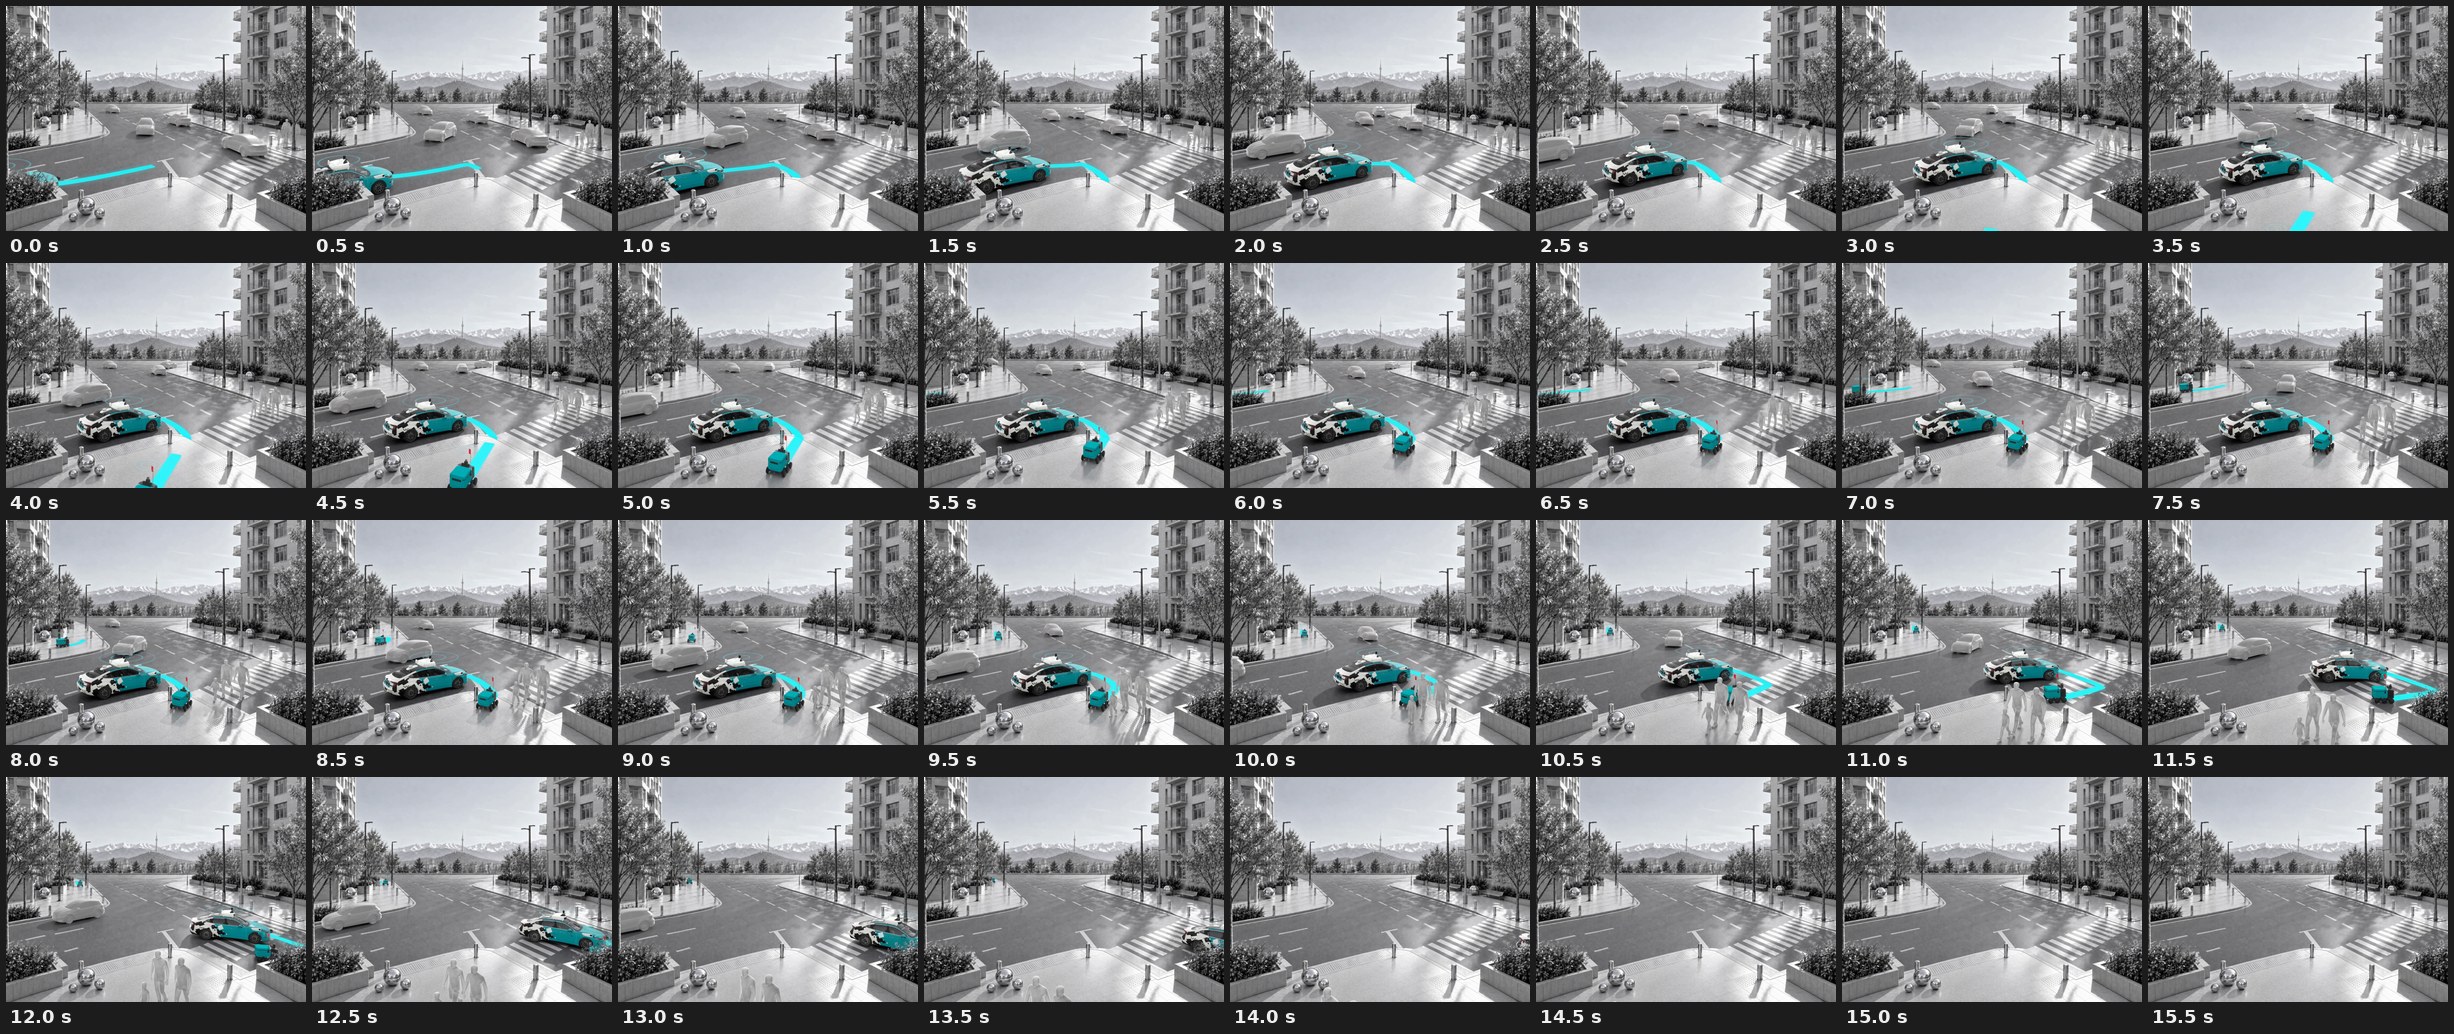
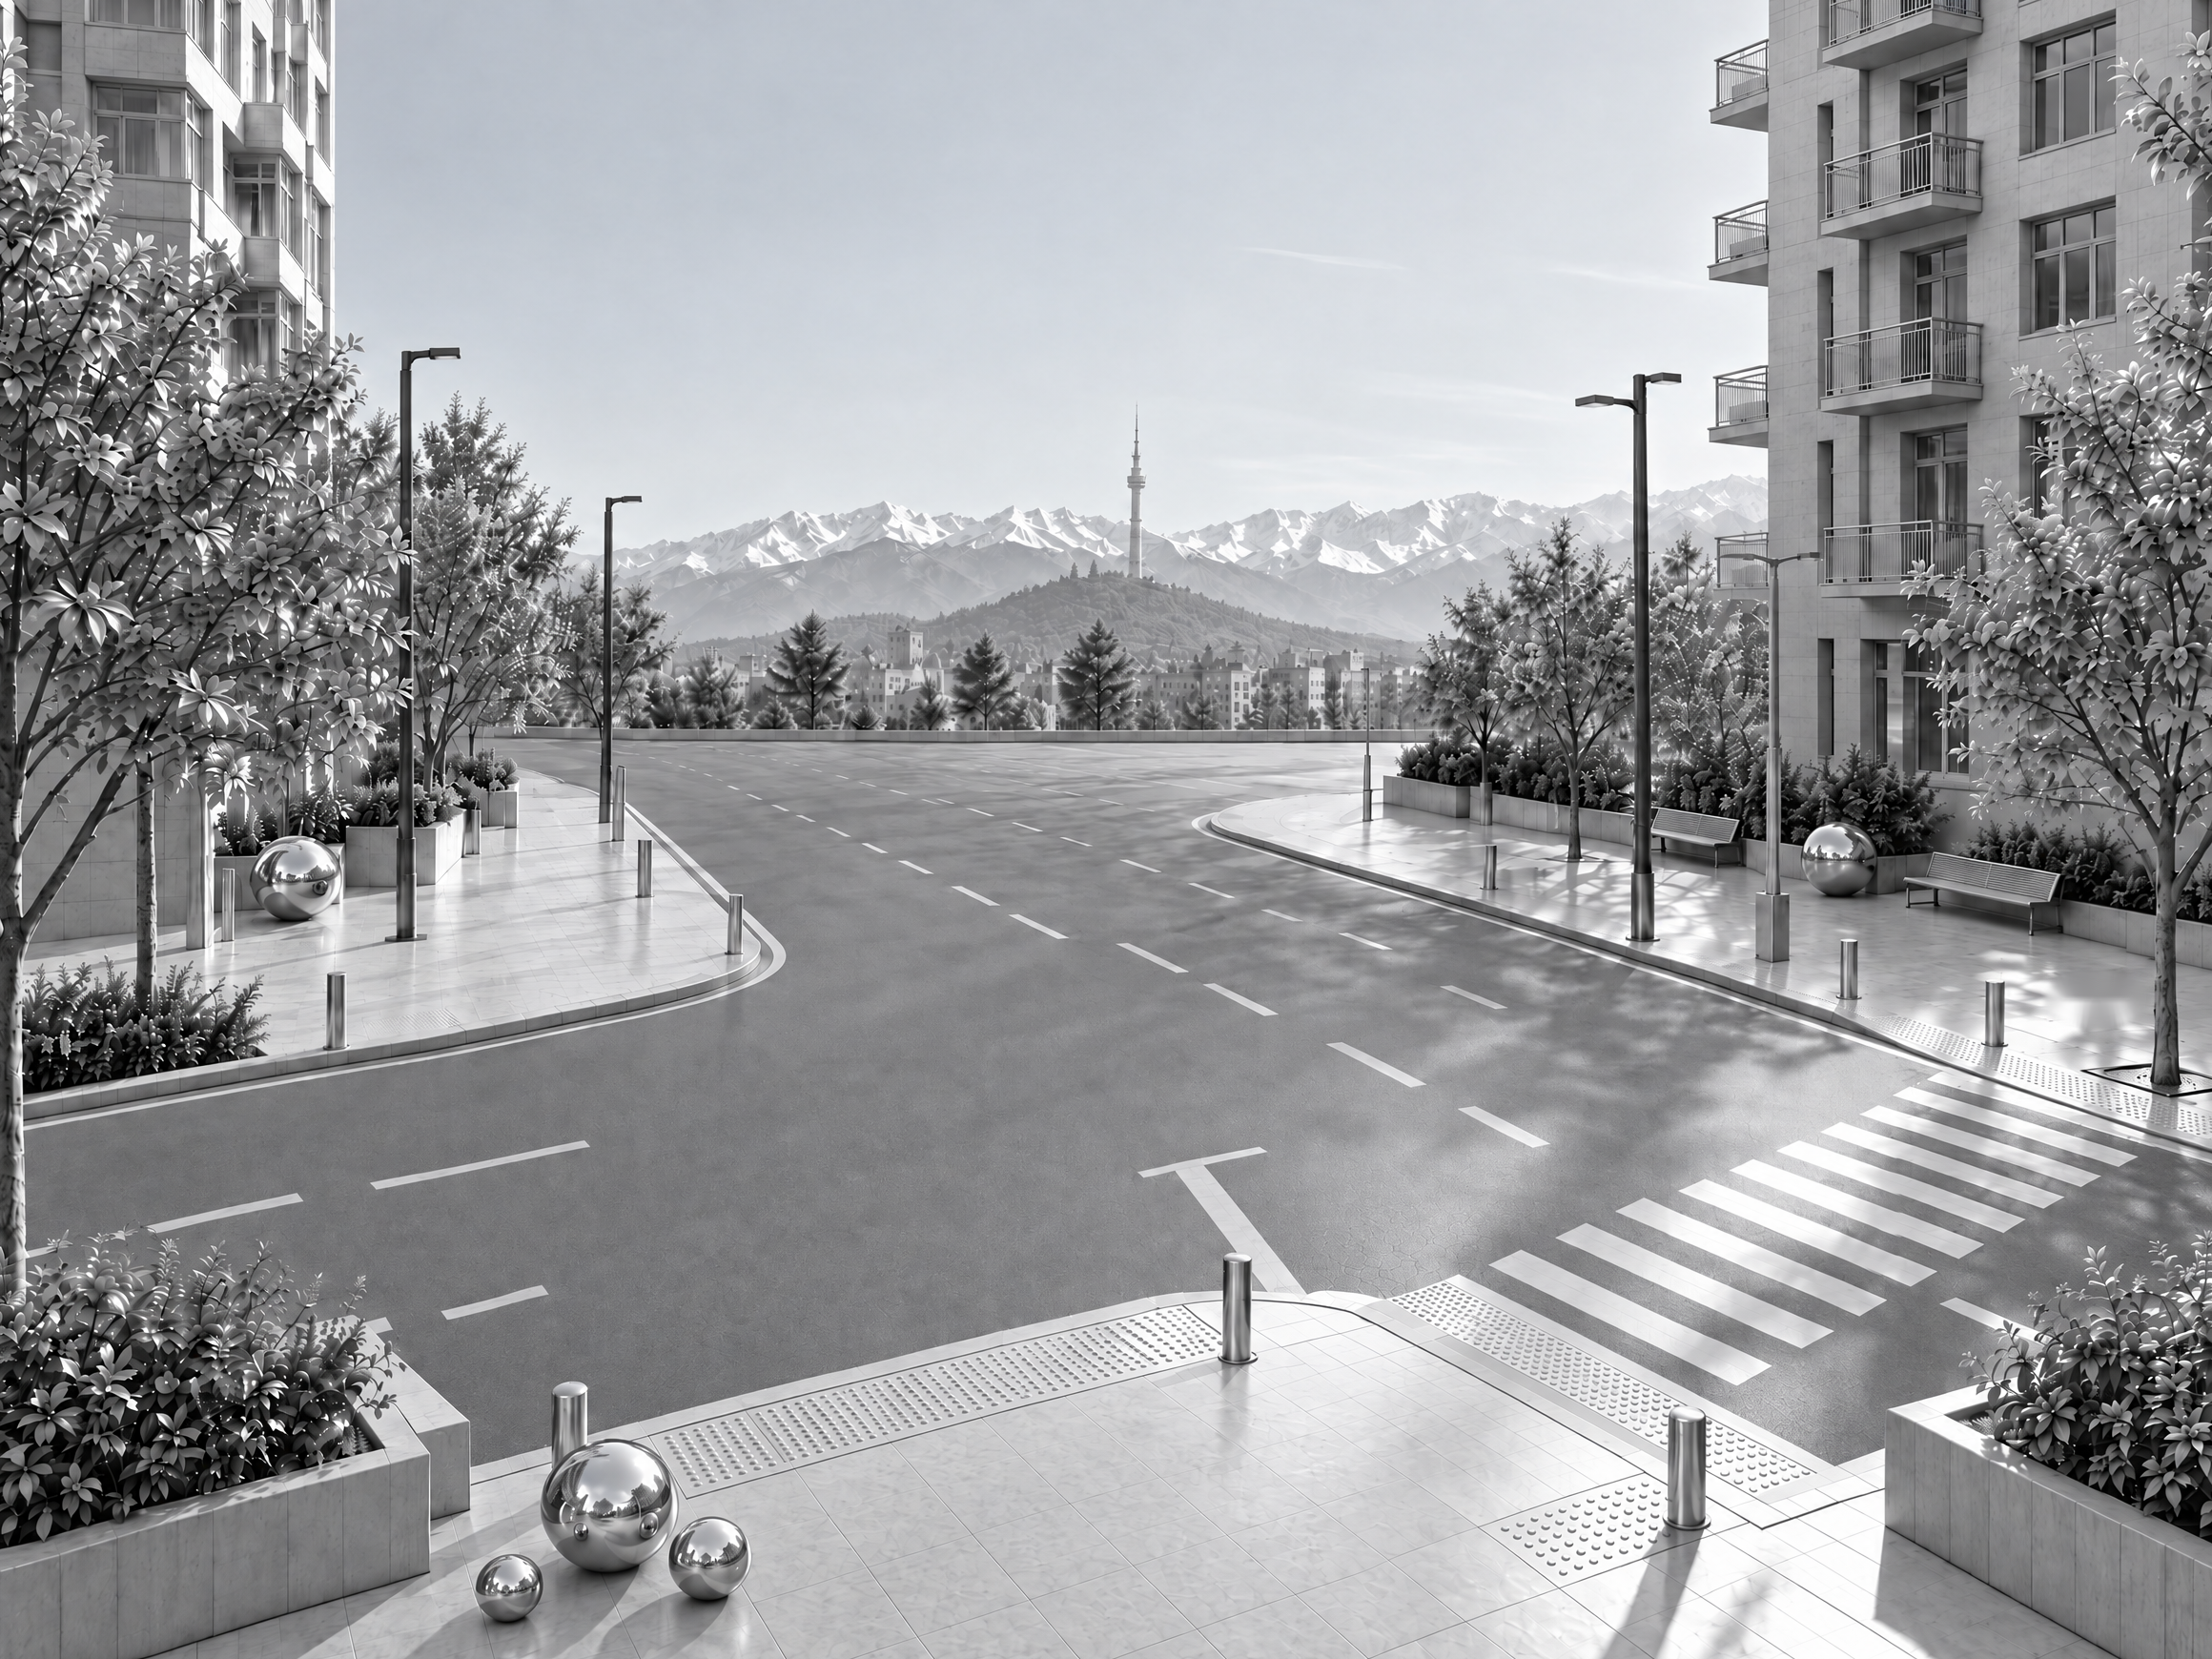
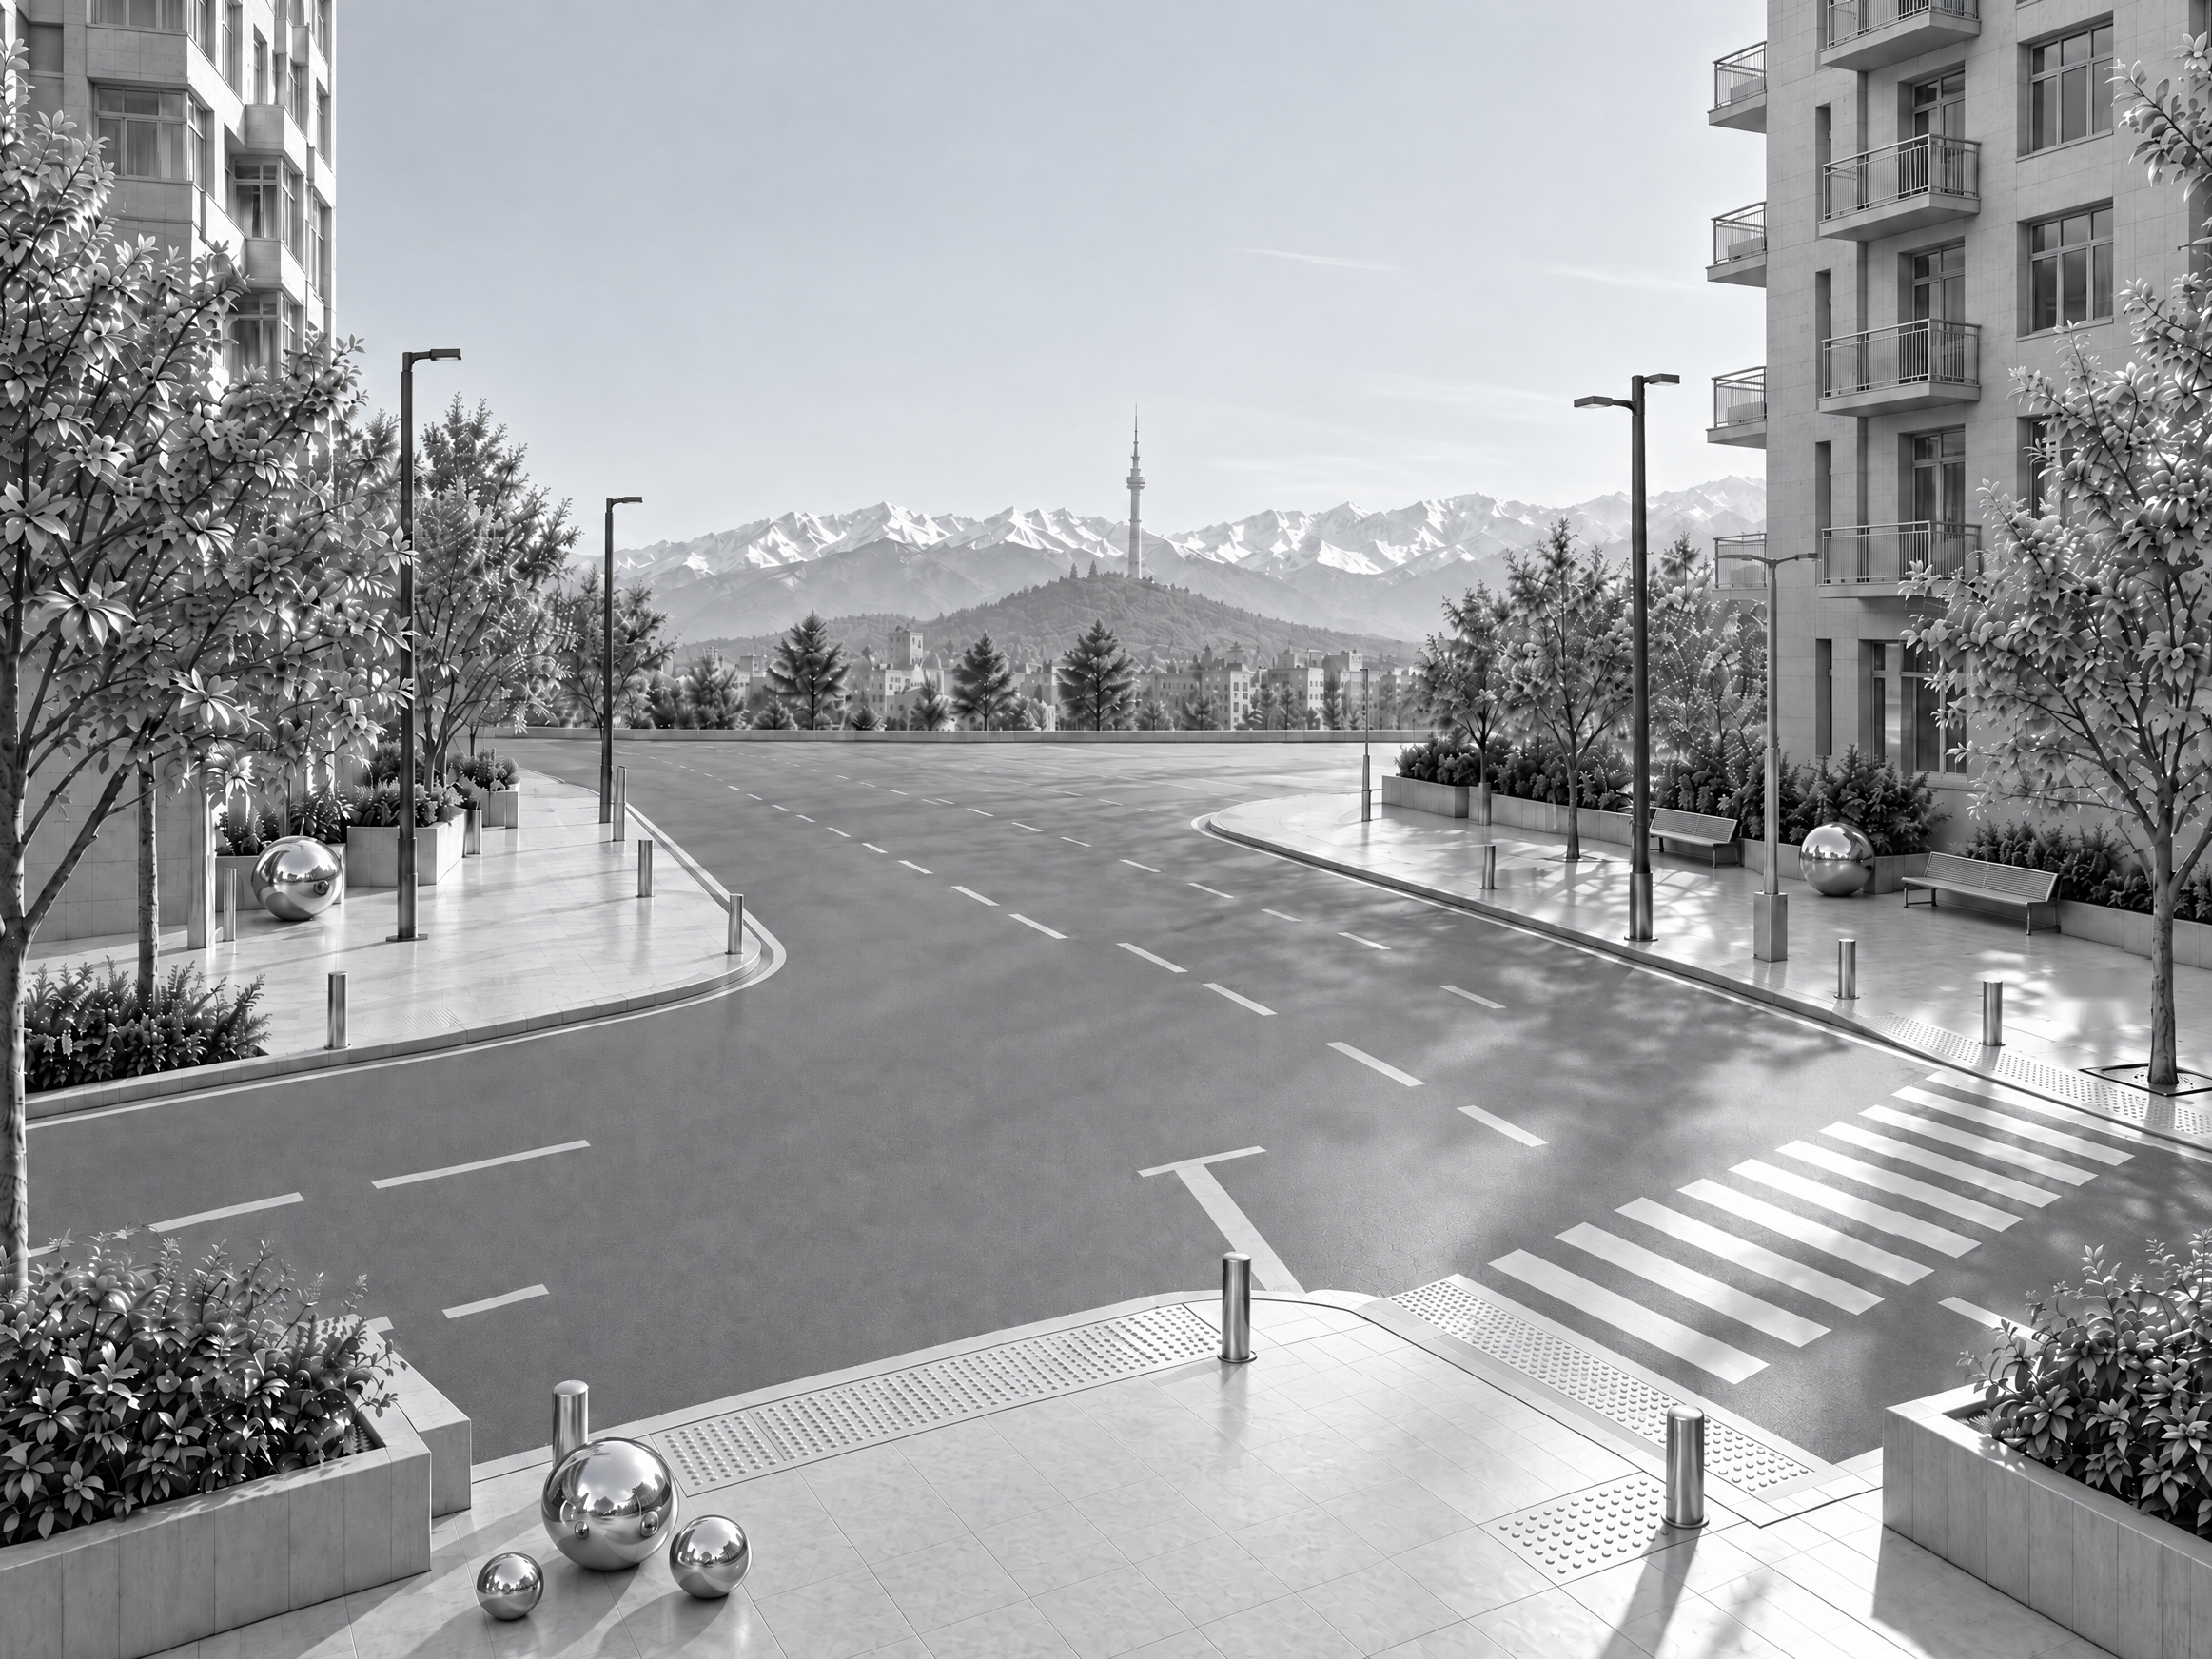
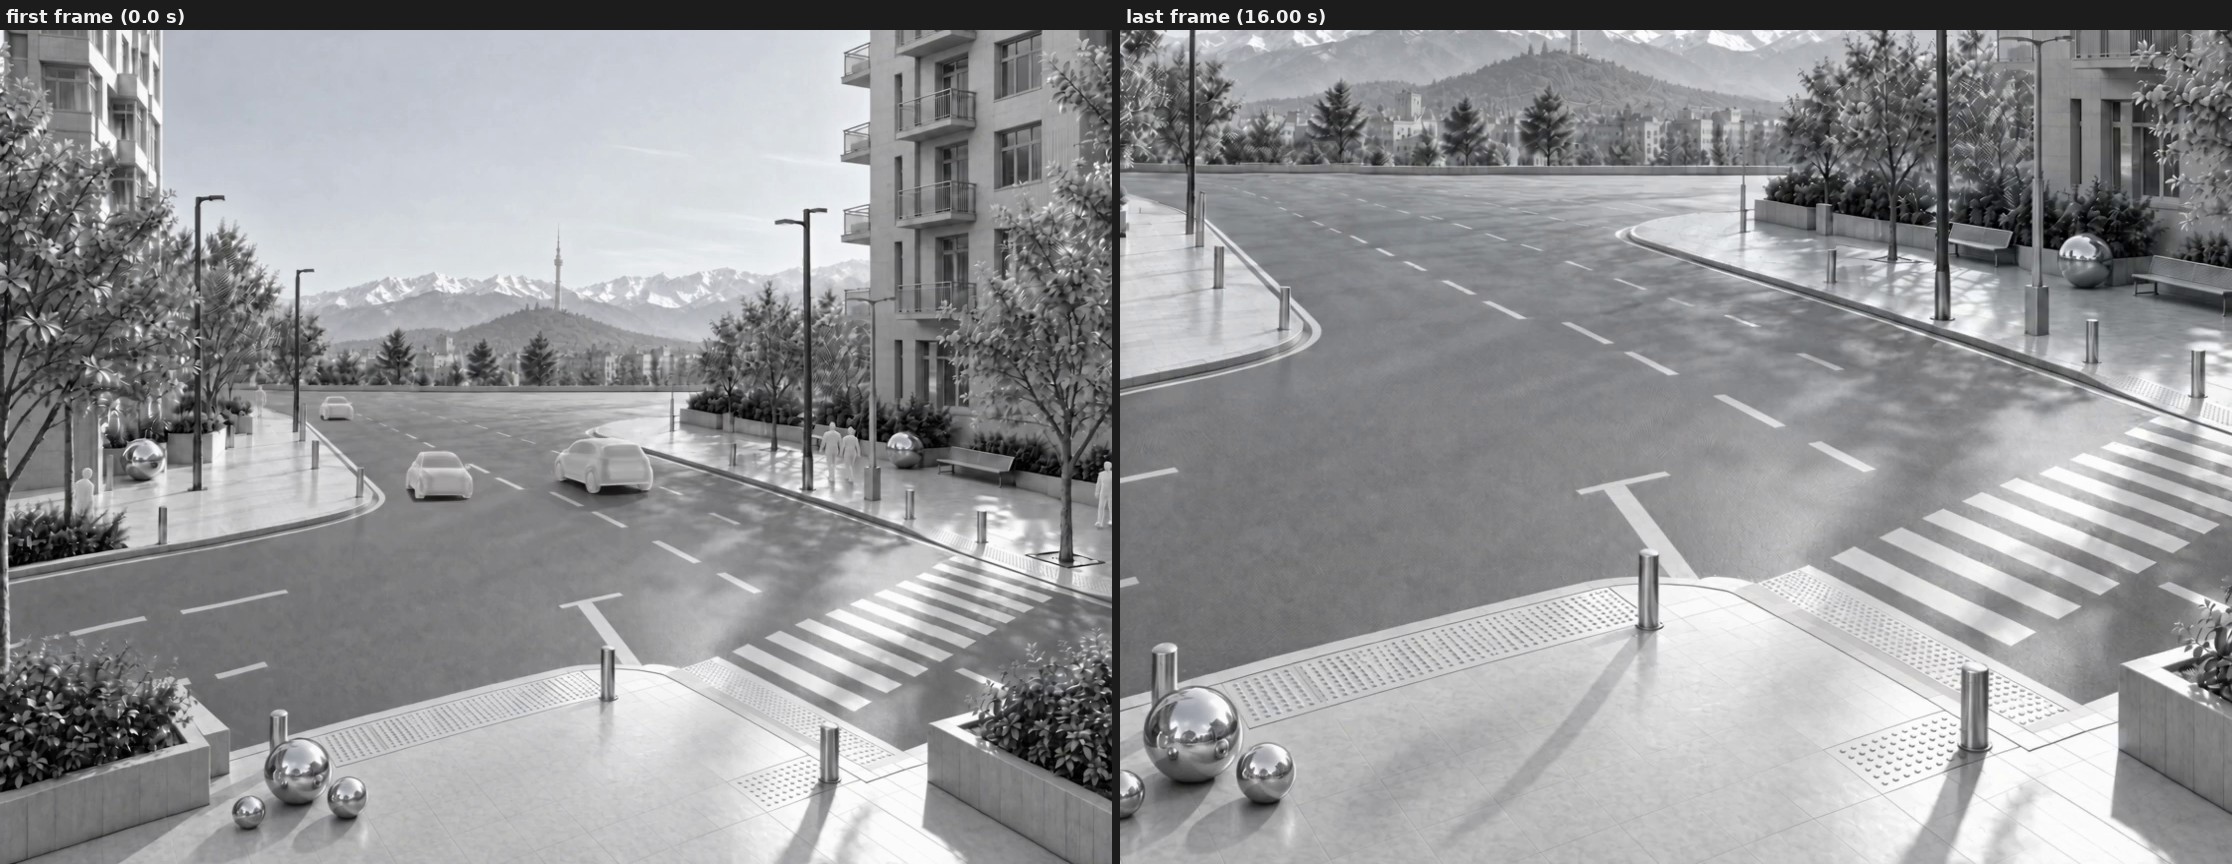
A seamless looping background video for a large event screen. The camera is locked off and never moves, zooms or drifts. The lighting, sky, shadows and every fixed thing in the location stay exactly as in image 1 from first frame to last. No fade in, no fade out, no cuts. The first frame and the last frame are the same: the empty street of image 1. Everything that moves enters from outside the frame, passes through and leaves it again.

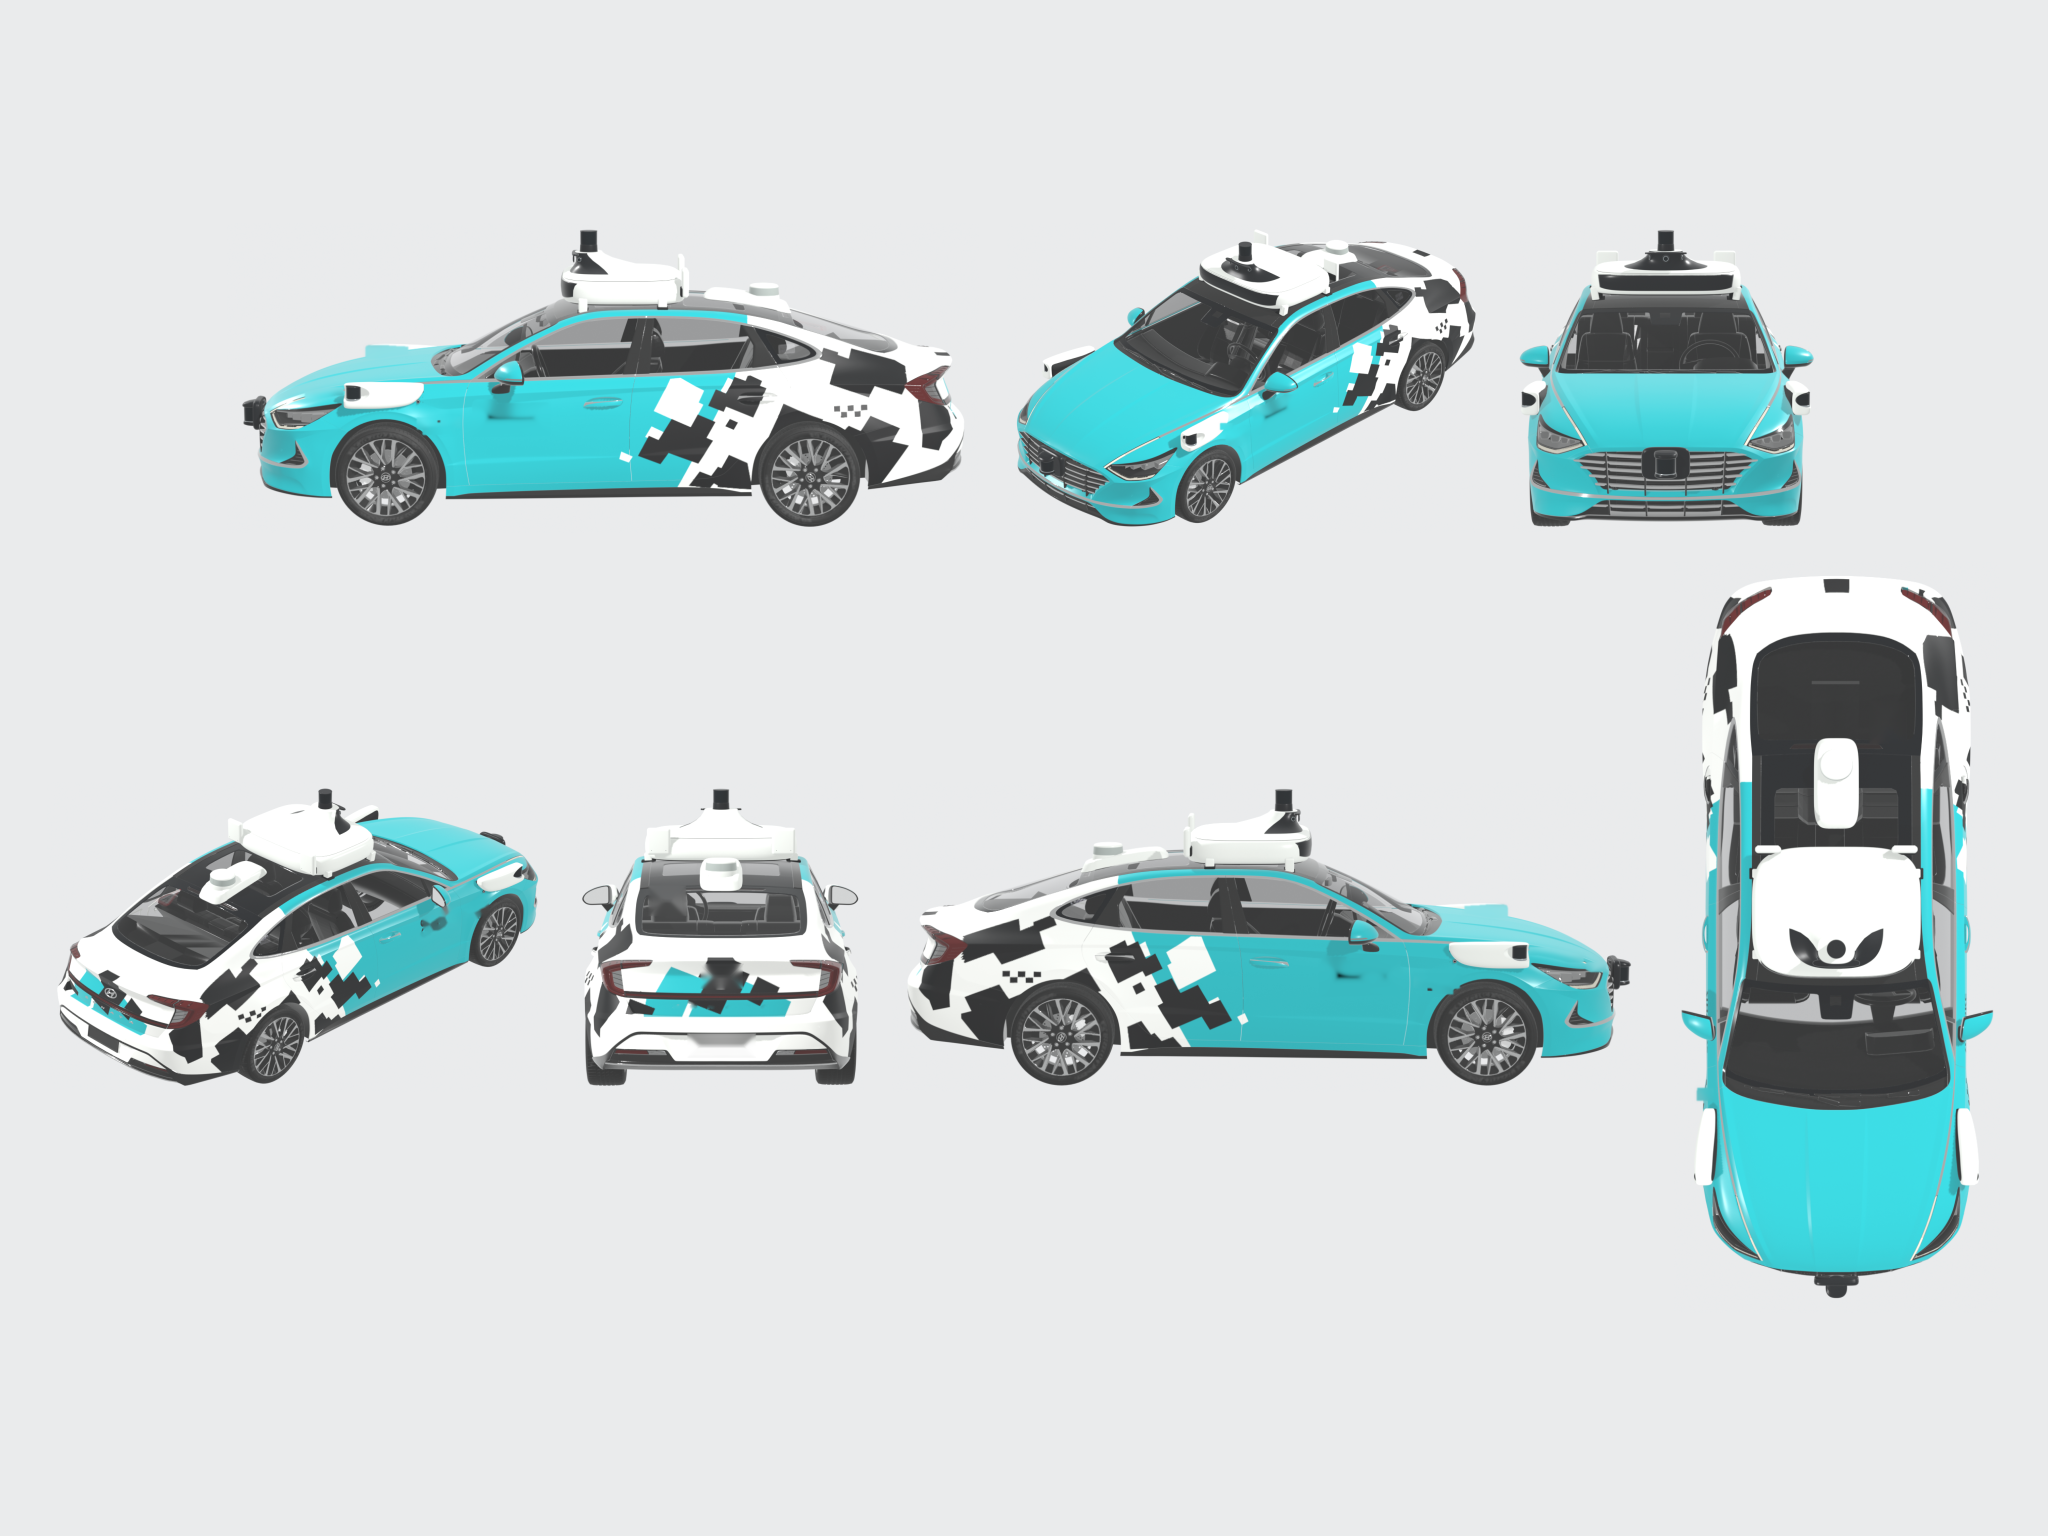
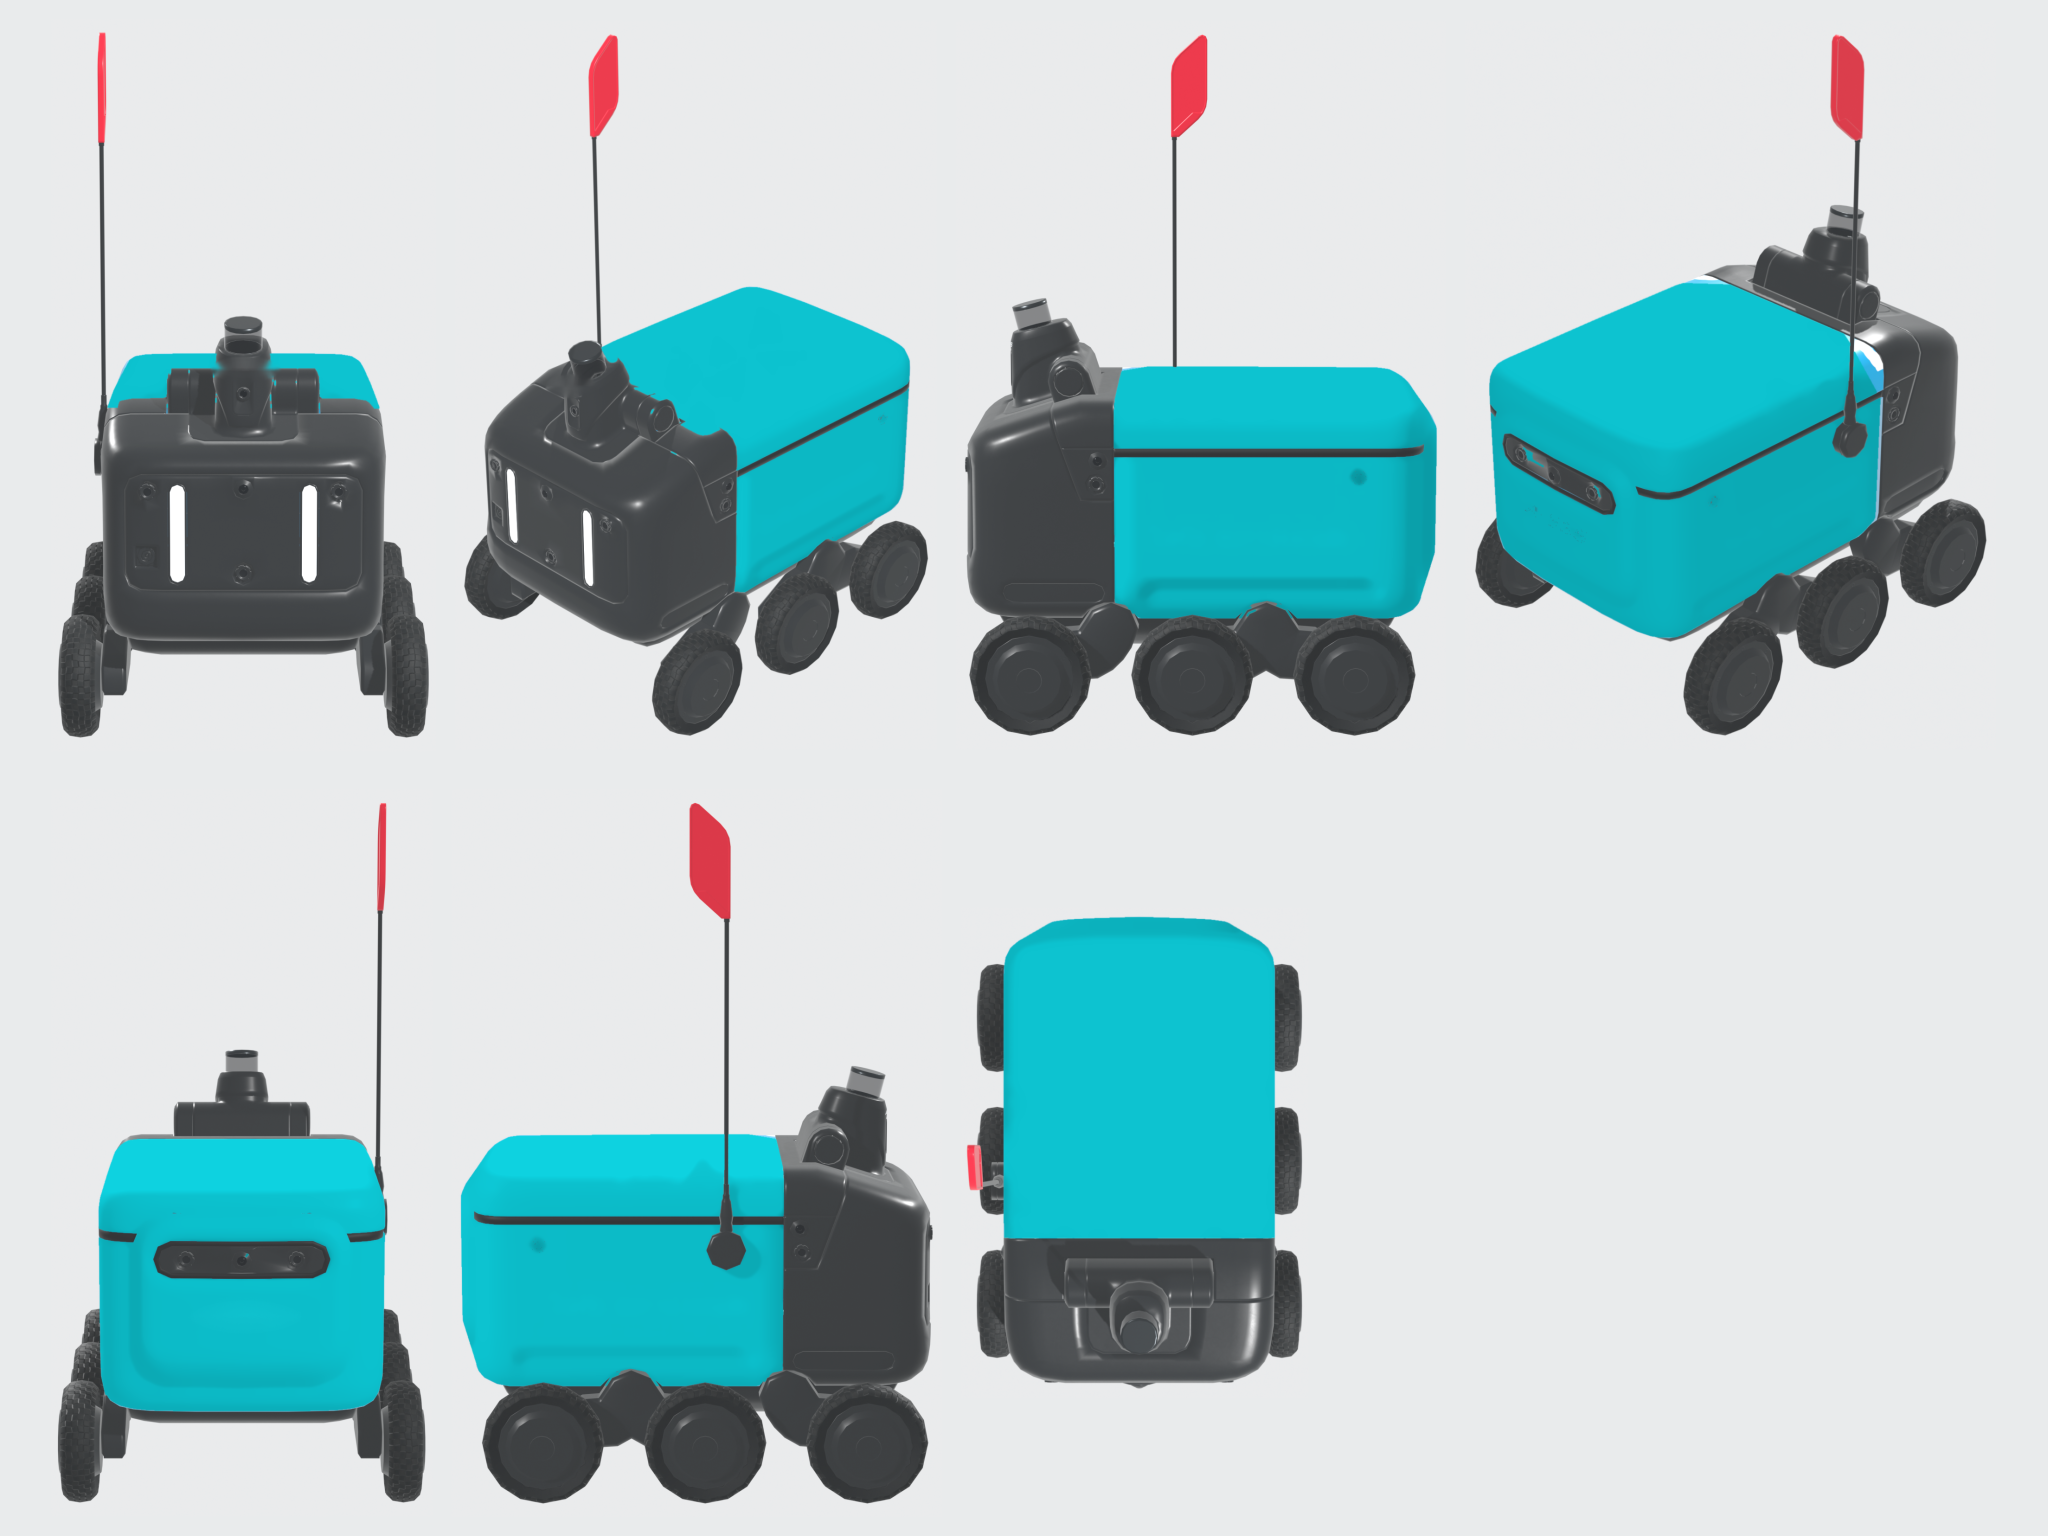
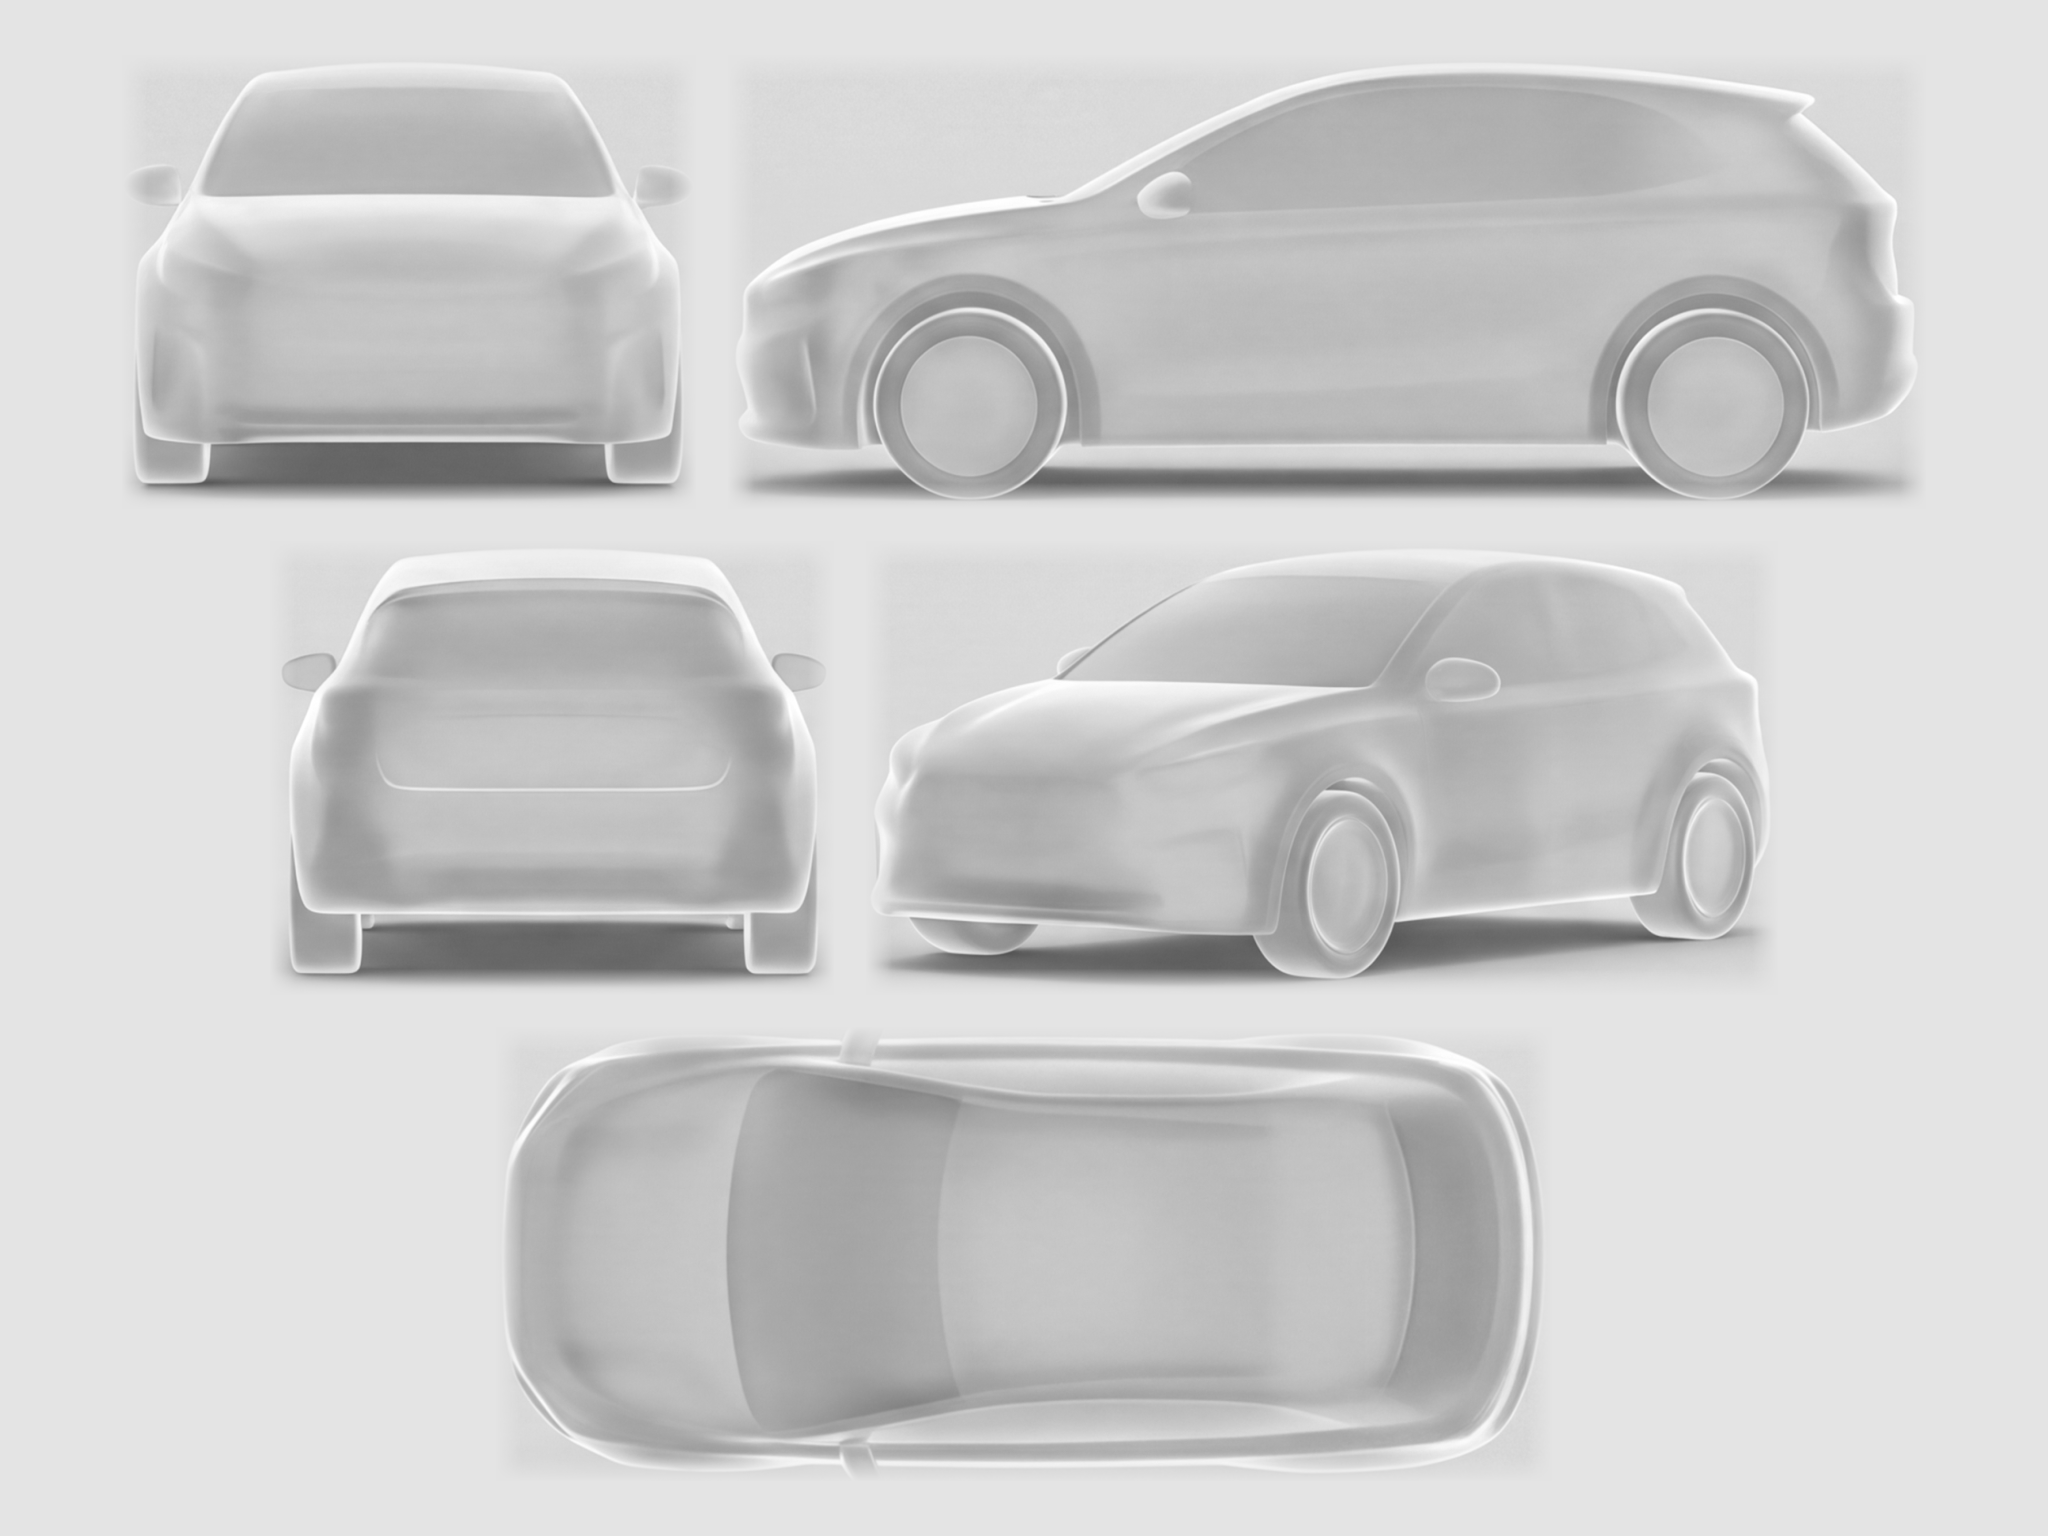
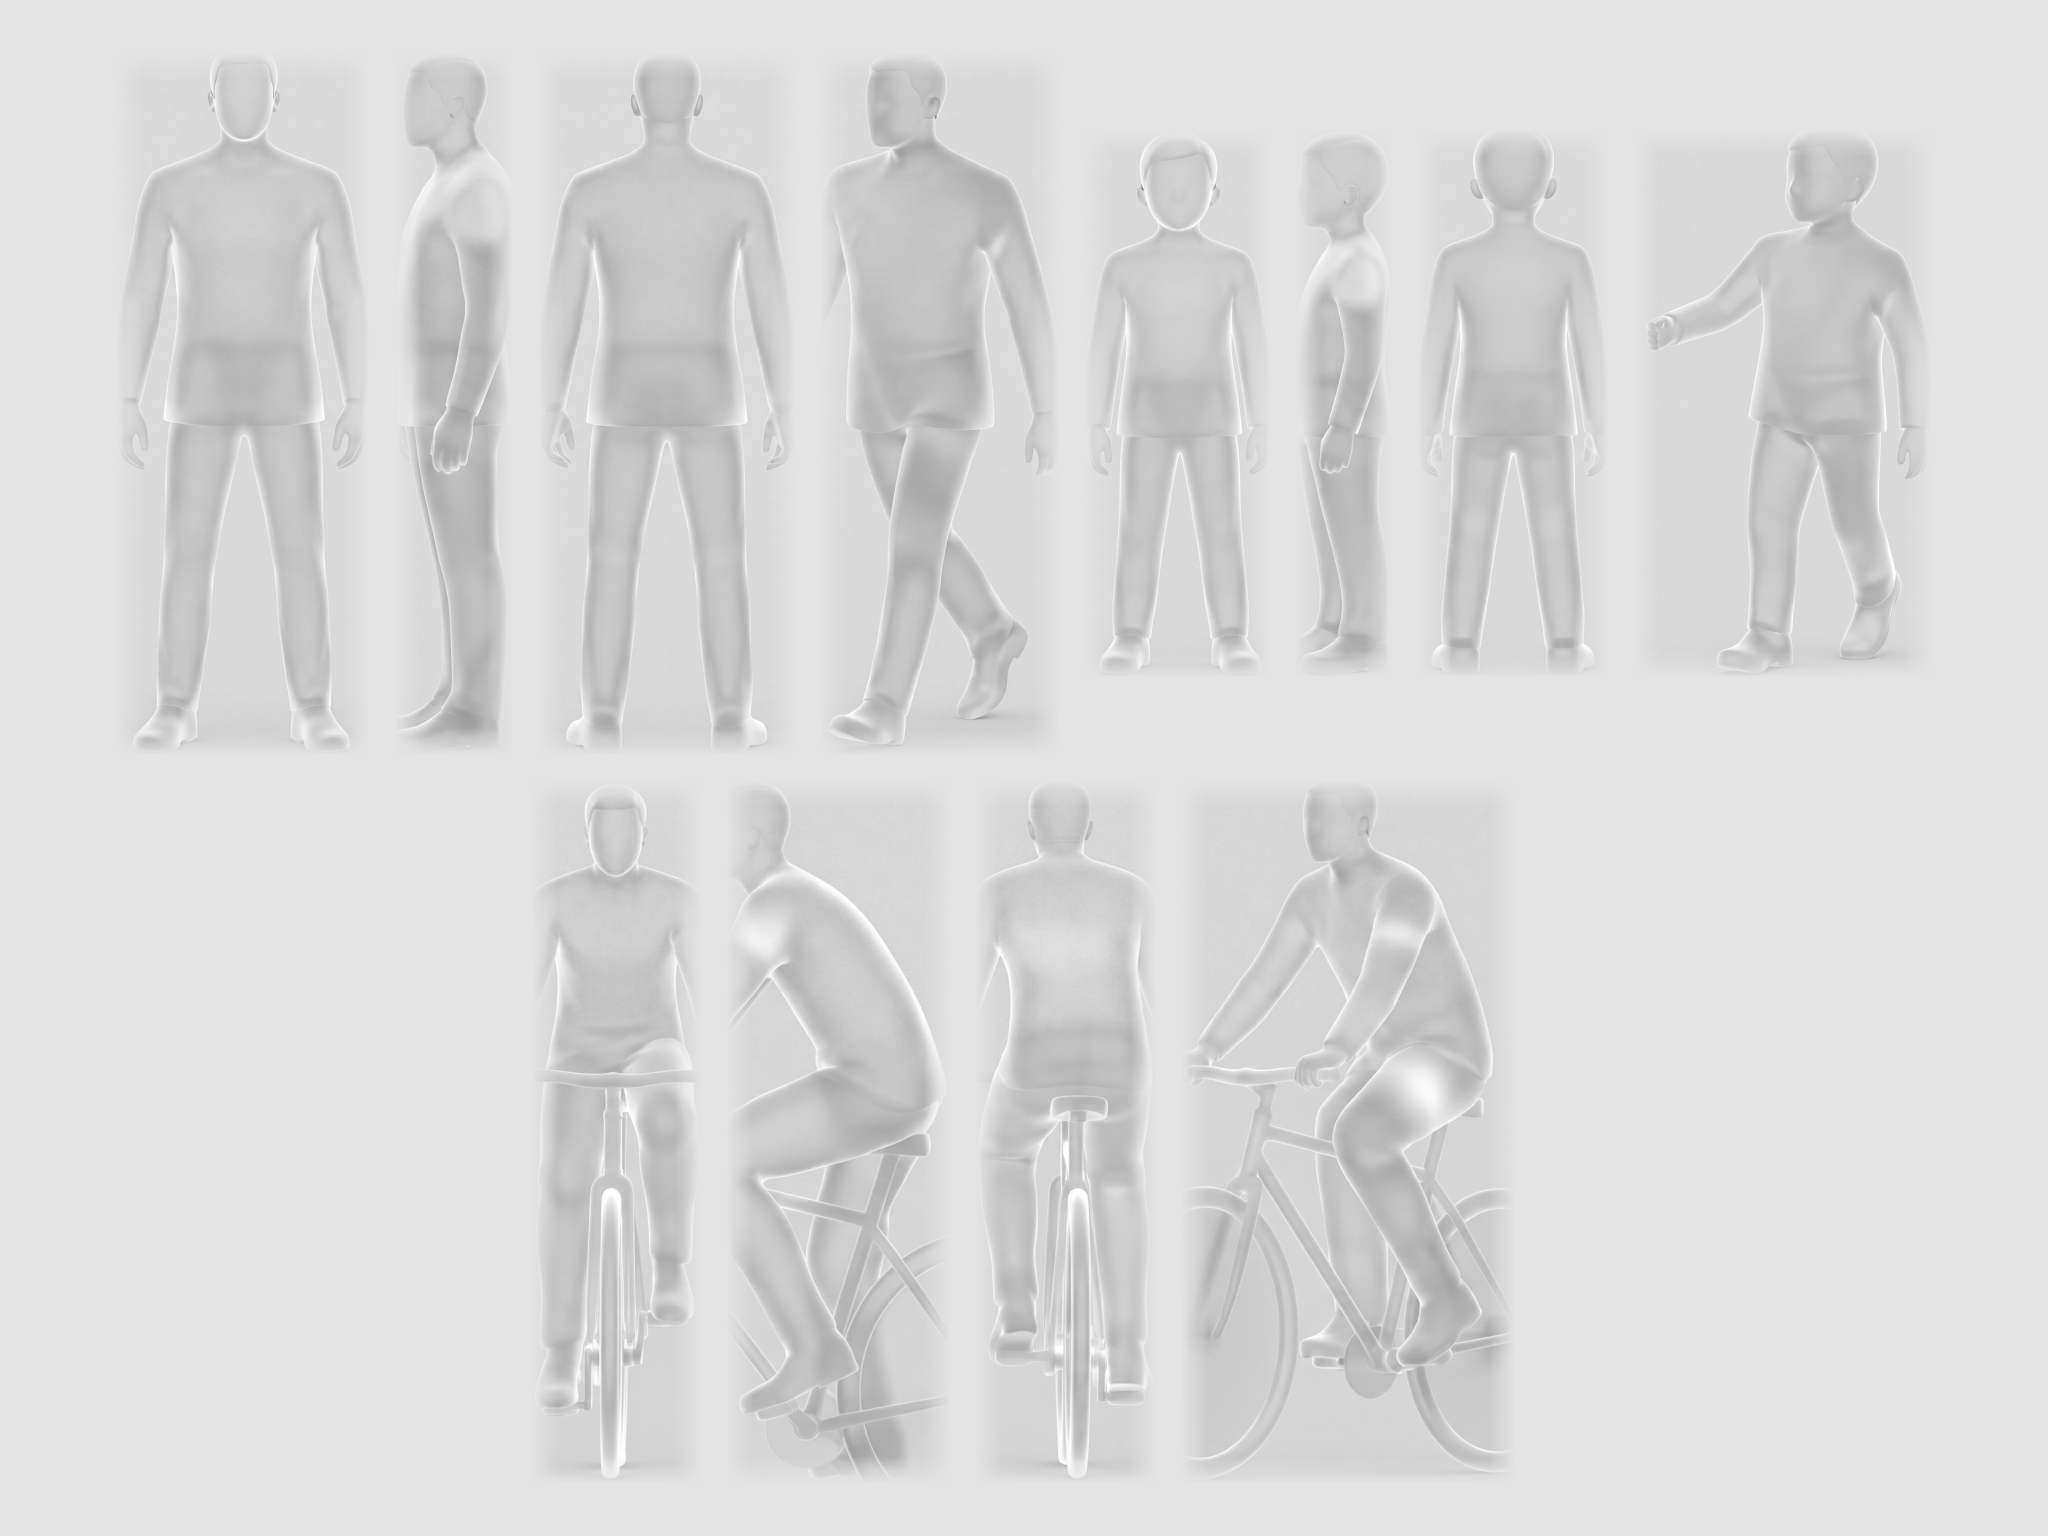
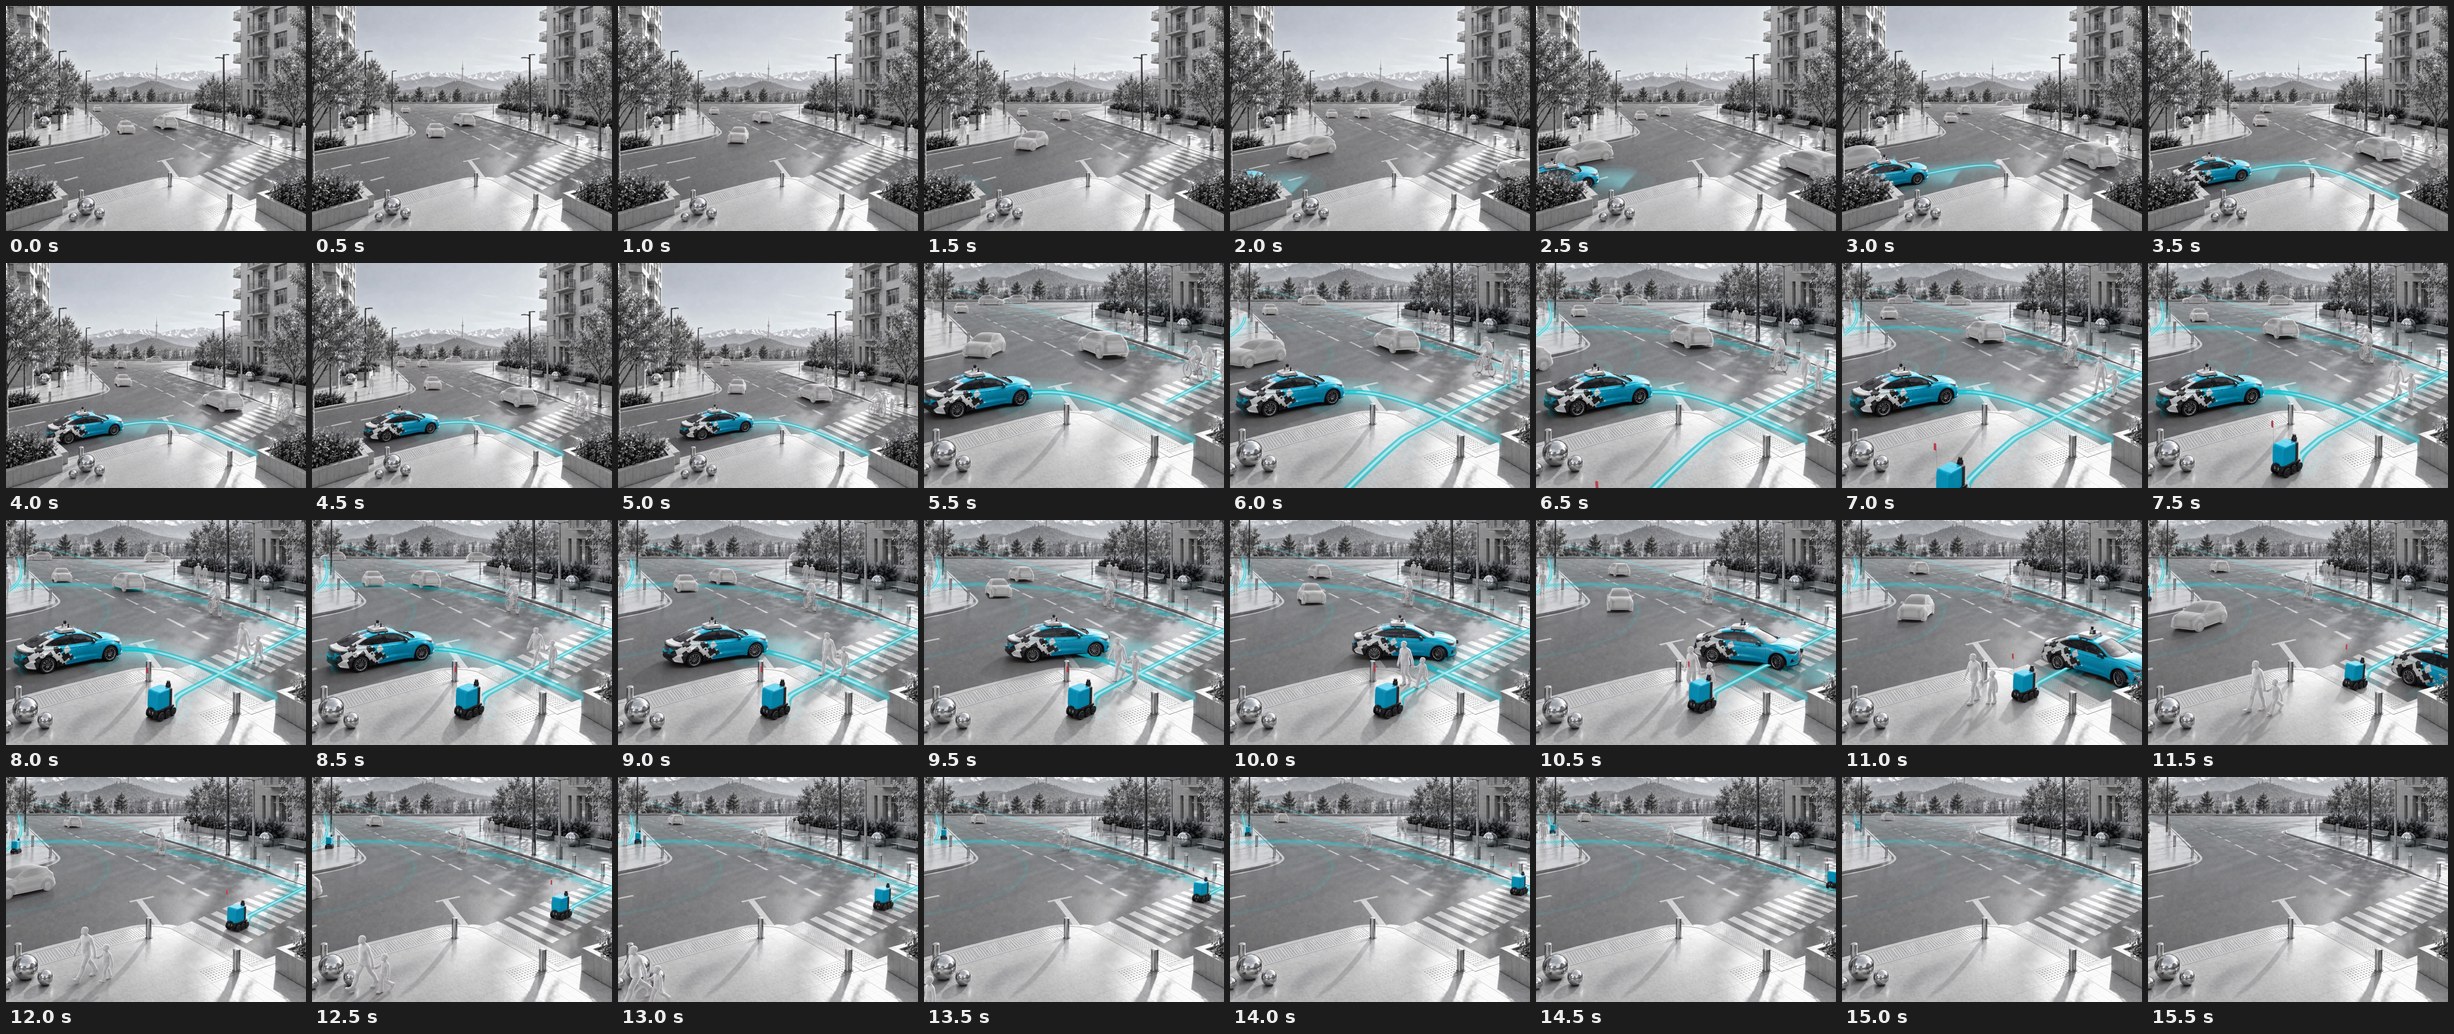
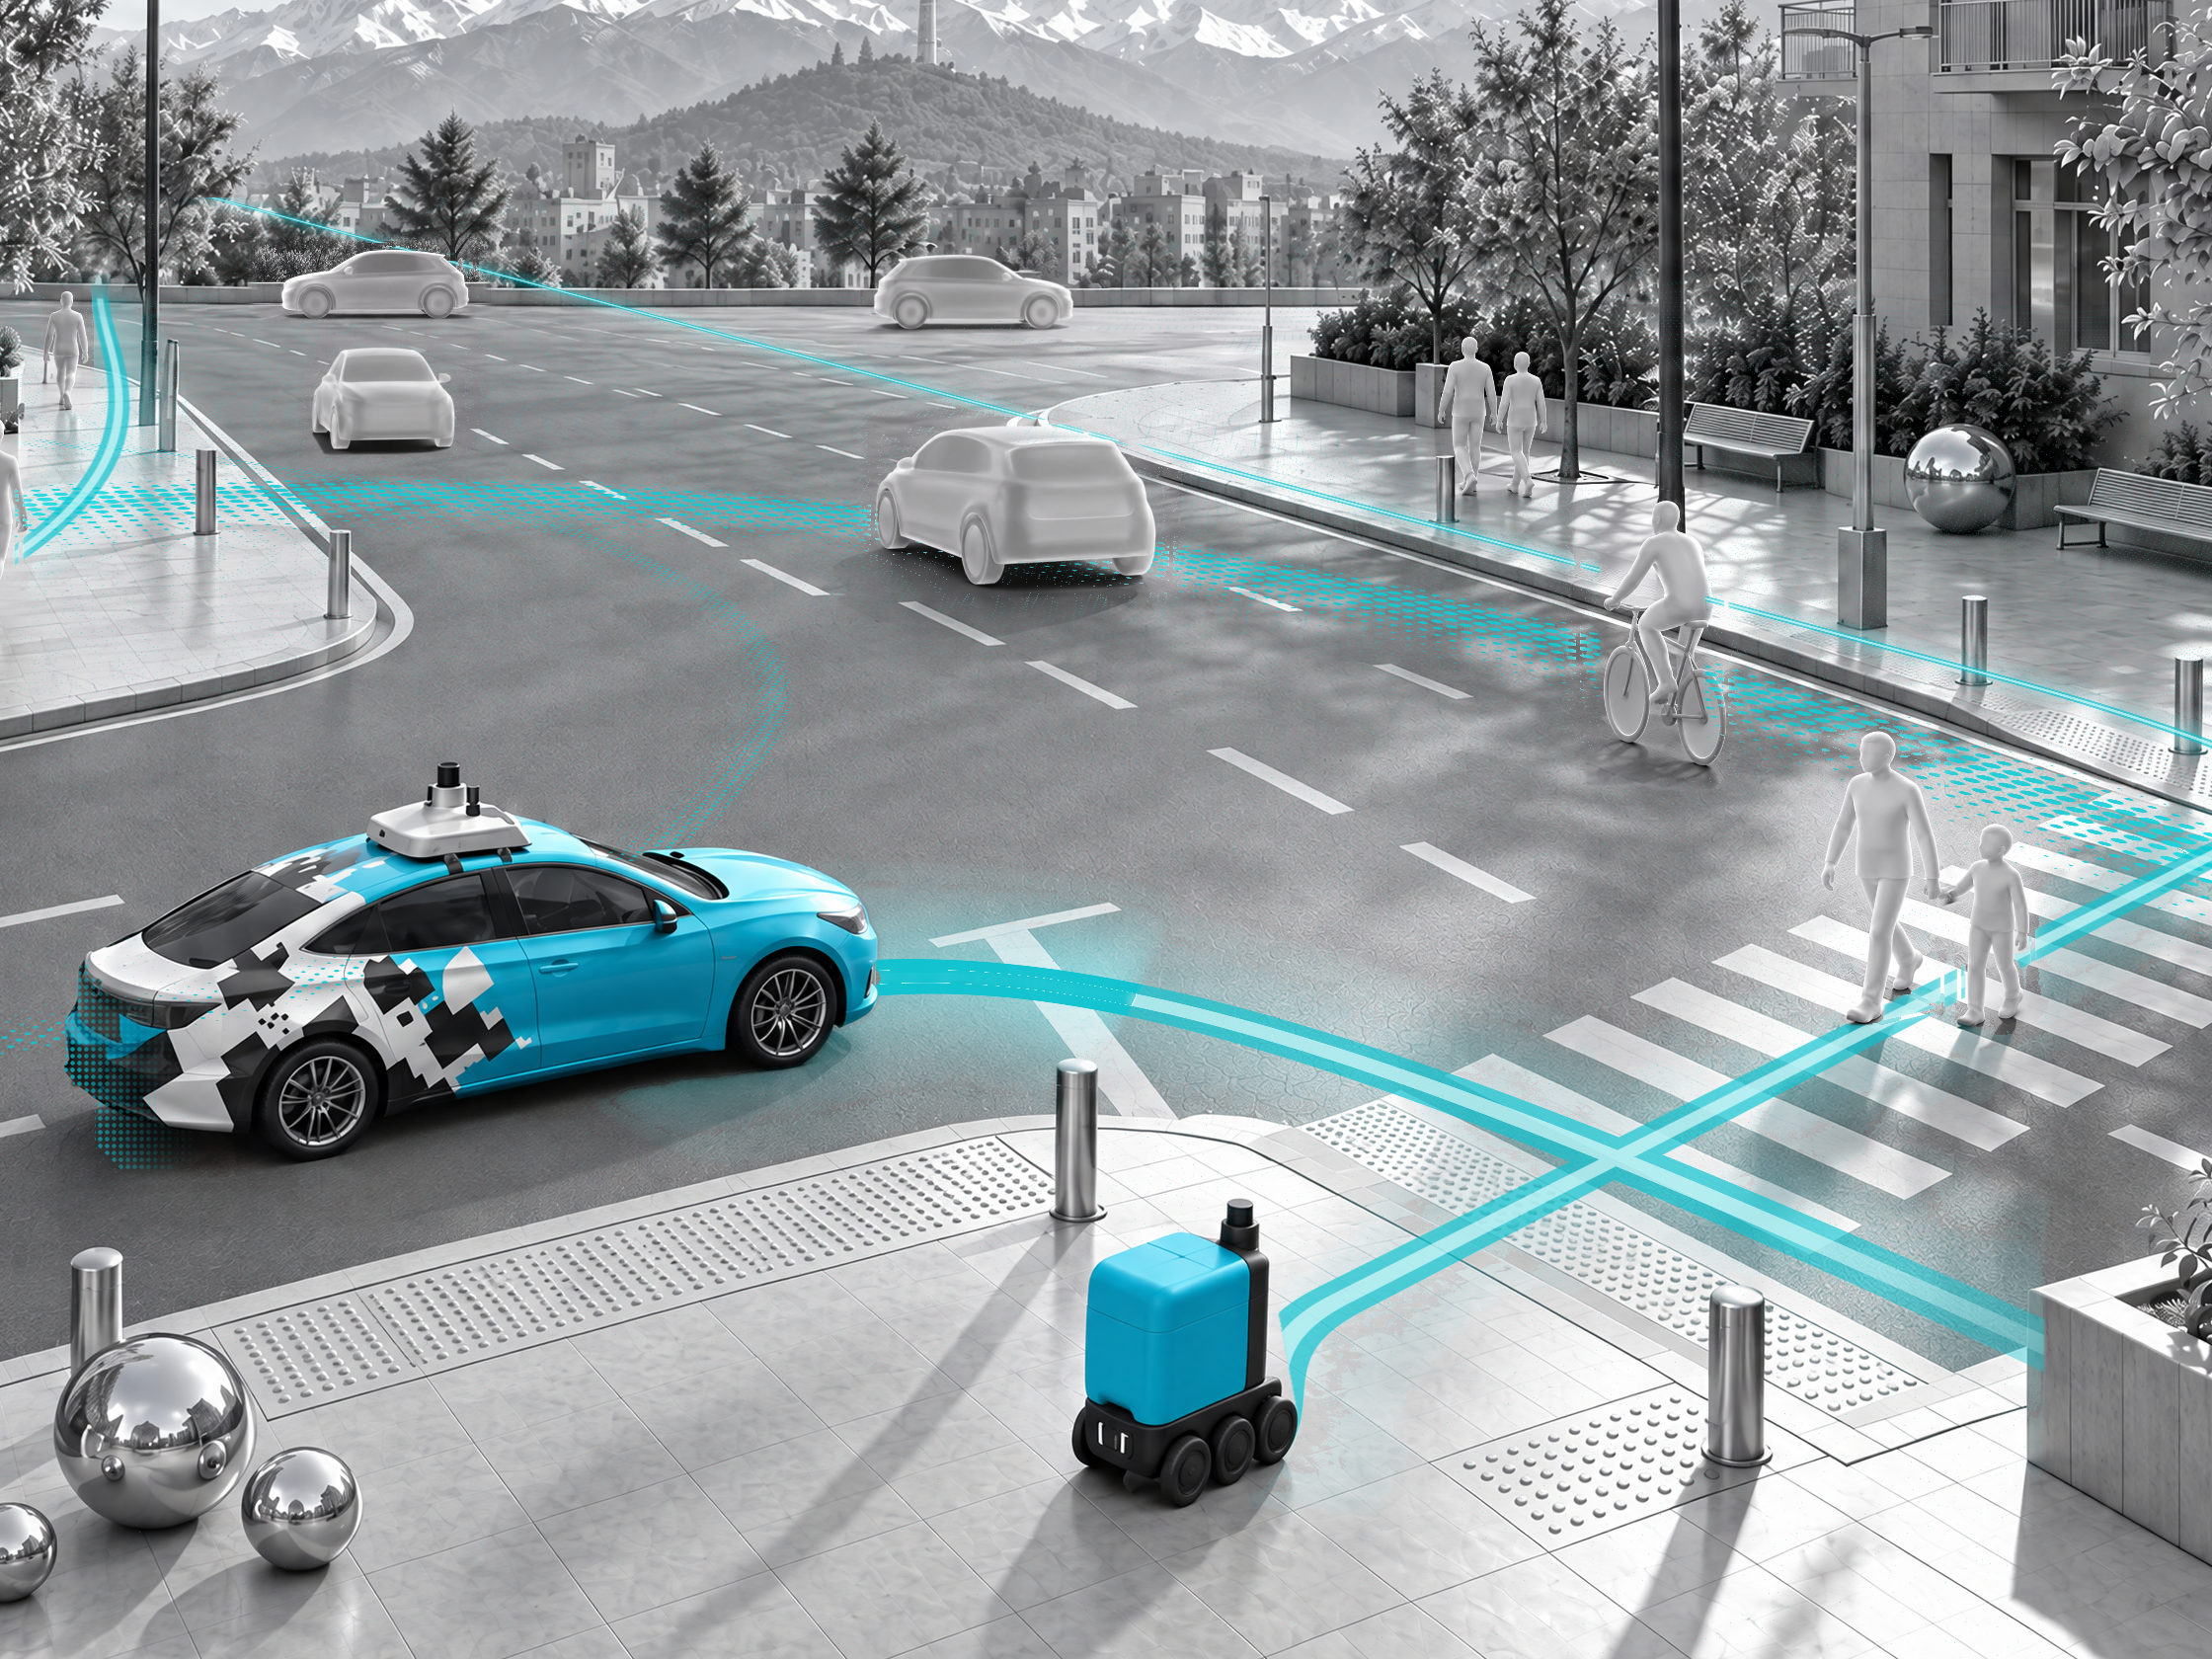
The location is image 1 in exactly its framing, lens and perspective. A turquoise robotaxi (image 2) enters from the bottom of the frame along the side street on the left, drives up its lane to the white stop line at the mouth of the side street and stops there only while the crossing ahead is in use; once it is clear it turns right across the zebra crossing onto the main road and drives out of the frame on the right. It pulls out only into a clear lane: vehicles never touch, overlap or pass through one another, and every car keeps a full car length from the next. Two identical turquoise delivery rovers (image 3) roll only on the pedestrian paving, never in a traffic lane and never next to a car; the only asphalt a rover ever touches is the zebra crossing. The lower rover enters from the bottom edge onto the near plaza, rolls to the landing of the crossing, waits there only while an adult and a child walk across the zebra toward it, then rolls across the zebra itself to the far sidewalk, turns right and leaves the frame on the right. The upper rover enters from the left edge onto the sidewalk of the left plaza, rolls along that sidewalk away from the camera and leaves the frame at the far end. The adult and child cross the zebra from the right sidewalk to the near plaza without pausing, walk on across the plaza and leave at the bottom of the frame. Ordinary traffic looks like the frosted milky-white car of image 4 and flows through steadily. Other pedestrians and a cyclist look like the frosted faceless figures of image 5. Every person walks at a steady pace the whole time: nobody stands, waits, turns around or lingers. The vehicles wait for people; people never wait for vehicles. By the end everyone has walked or driven out of the frame and the street is empty again.

Lidar: from the robotaxi's roof sensor a thin ring of small turquoise dots starts, expands outward along the ground like a ripple on water and fades as it grows; a new ring appears about every second, so two or three rings are always visible. The sensor head of each rover emits the same rings, smaller. The rings are there the whole time each vehicle is in the frame. Not a beam, not a headlight, not a cone of light, not fog.

Path line: a thick glowing turquoise ribbon lies flat on the asphalt directly ahead of the robotaxi, one lane wide, starting under its front bumper and showing the route it is about to drive. At the stop line the ribbon ends at the line and pulses gently; when the car moves, the ribbon curves right across the crossing and the car follows it. Each rover has the same ribbon, narrower, on the paving ahead of it, showing its route across the crossing or along the sidewalk. Every ribbon moves with its vehicle and is visible the whole time the vehicle is in the frame. Not an arrow, no arrowheads, not dashes.

Turquoise is the only colour: the robotaxi, the rover lids, the lidar rings and the ribbons (the rovers' small red flag stays as it is). Everything else is silver-grey monochrome, photoreal CGI, daylight. No white boxes or frames, no arrows, diagrams or interface graphics, no text, letters, numbers, logos, plates, signs, watermarks or faces.
A seamless looping background video for a large event screen. The camera is locked off and never moves, zooms or drifts. The lighting, sky, shadows and every fixed thing in the location stay exactly as in image 1 from first frame to last. No fade in, no fade out, no cuts. The first frame and the last frame are the same: the empty street of image 1. Everything that moves enters from outside the frame, passes through and leaves it again.

The location is image 1 in exactly its framing, lens and perspective. A turquoise robotaxi (image 2) enters from the bottom of the frame along the side street on the left, drives up its lane to the white stop line at the mouth of the side street and stops there only while the crossing ahead is in use; once it is clear it turns right across the zebra crossing onto the main road and drives out of the frame on the right. It pulls out only into a clear lane: vehicles never touch, overlap or pass through one another, and every car keeps a full car length from the next. Two identical turquoise delivery rovers (image 3) roll only on the pedestrian paving, never in a traffic lane and never next to a car; the only asphalt a rover ever touches is the zebra crossing. The lower rover enters from the bottom edge onto the near plaza, rolls to the landing of the crossing, waits there only while an adult and a child walk across the zebra toward it, then rolls across the zebra itself to the far sidewalk, turns right and leaves the frame on the right. The upper rover enters from the left edge onto the sidewalk of the left plaza, rolls along that sidewalk away from the camera and leaves the frame at the far end. The adult and child cross the zebra from the right sidewalk to the near plaza without pausing, walk on across the plaza and leave at the bottom of the frame. Ordinary traffic looks like the frosted milky-white car of image 4 and flows through steadily. Other pedestrians and a cyclist look like the frosted faceless figures of image 5. Every person walks at a steady pace the whole time: nobody stands, waits, turns around or lingers. The vehicles wait for people; people never wait for vehicles. By the end everyone has walked or driven out of the frame and the street is empty again.

Lidar: from the robotaxi's roof sensor a thin ring of small turquoise dots starts, expands outward along the ground like a ripple on water and fades as it grows; a new ring appears about every second, so two or three rings are always visible. The sensor head of each rover emits the same rings, smaller. The rings are there the whole time each vehicle is in the frame. Not a beam, not a headlight, not a cone of light, not fog.

Path line: a thick glowing turquoise ribbon lies flat on the asphalt directly ahead of the robotaxi, one lane wide, starting under its front bumper and showing the route it is about to drive. At the stop line the ribbon ends at the line and pulses gently; when the car moves, the ribbon curves right across the crossing and the car follows it. Each rover has the same ribbon, narrower, on the paving ahead of it, showing its route across the crossing or along the sidewalk. Every ribbon moves with its vehicle and is visible the whole time the vehicle is in the frame. Not an arrow, no arrowheads, not dashes. The lidar rings and the path ribbons look exactly like the turquoise rings and ribbons in image 6; image 6 shows only their look, not where anything is.

Turquoise is the only colour: the robotaxi, the rover lids, the lidar rings and the ribbons (the rovers' small red flag stays as it is). Everything else is silver-grey monochrome, photoreal CGI, daylight. No white boxes or frames, no arrows, diagrams or interface graphics, no text, letters, numbers, logos, plates, signs, watermarks or faces.